Vectors (A2 Unit 4: Applied Mathematics B) — WJEC A-Level Mathematics
Vectors (A2 Unit 4: Applied Mathematics B) explained
Vectors (A2 Unit 4: Applied Mathematics B) covers 2 specification points, including Understand and use vectors in three dimensions.
Read the full explanation
and Use vectors to solve problems in context,…. Open a point below for its explanation and revision guidance.
Understand and use vectors in three dimensions.
Three-dimensional vectors represent positions, velocities and forces using orthogonal unit vectors i, j and k along the x, y and z axes: r = xi + yj + zk, or as a column vector (x, y, z)ᵀ. Magnitude extends Pythagoras: |r| = √(x² + y² + z²). The distance between A(x₁, y₁, z₁) and B(x₂, y₂, z₂) is |AB| = √((x₂ − x₁)² + (y₂ − y₁)² + (z₂ − z₁)²), where AB = r_B − r_A. A unit vector is r̂ = r / |r|. The scalar product is a · b = a_x b_x + a_y b_y + a_z b_z, and a · b = |a||b|cos θ gives the angle between vectors, so cos θ = (a · b)/(|a||b|). For example, if a = i + 2j + 2k and b = 2i − j + 2k, then a · b = 2 − 2 + 4 = 4, |a| = |b| = 3, so cos θ = 4/9 and θ ≈ 63.6°.
Use vectors to solve problems in context, including forces and kinematics.
Three-dimensional vectors model physical forces, particle velocities, and positions in spatial environments (such as aircraft flight paths or naval navigation). When multiple 3D forces act on a body, their resultant is R = ΣF_i = (Σx_i)i + (Σy_i)j + (Σz_i)k. In equilibrium, the resultant vector is zero (R = 0), requiring balance in all three axes. Under Newton's second law, ΣF = ma applies in 3D. Kinematic equations with constant 3D acceleration extend to v = u + at and r = r₀ + ut + ½at². For variable acceleration, calculus applies component-wise: v = dr/dt and a = dv/dt. Candidates compute speed as |v| and distance from origin as |r|.
Watch and listen
Listen: Vectors (A2 Unit 4: Applied Mathematics B) audio lesson
Read the full guideVisual Resources
1 diagram and illustration
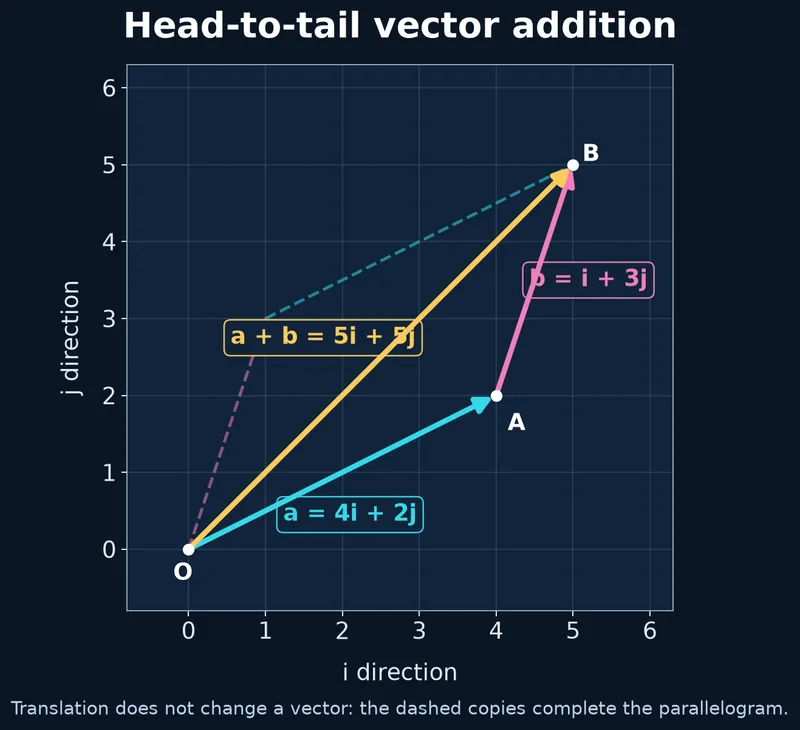
Interactive Diagrams
1 interactive diagram to visualise key concepts
Conceptual Flow Outline
Position vectors start at the origin; the displacement from A to B is end minus start, and P divides AB internally.
Your focus
- Represent 3D vectors using unit vectors i, j, k and column vector notation.
- Calculate magnitudes and distances between points in three-dimensional Cartesian space.
- Construct unit vectors parallel to given three-dimensional vectors.
Show all 7 objectives
- Use the scalar product to find the angle between two 3D vectors and to test perpendicularity.
- Solve 3D static equilibrium and dynamic problems by applying ΣF = 0 and ΣF = ma.
- Apply three-dimensional vector kinematics and calculus to model spatial particle trajectories.
- Compute scalar speeds, travel times, and spatial separations from 3D velocity and position vectors.
Vectors (A2 Unit 4: Applied Mathematics B) exam tips
Marking Points
- Calculate the magnitude of a 3D vector using |r| = √(x² + y² + z²), including all three components.
- Find the displacement vector between two 3D points using AB = r_B − r_A, then calculate its magnitude for the distance.
- Construct a unit vector in a specified 3D direction by dividing each component by the magnitude: r̂ = r / |r|.
- Evaluate the scalar product a · b = a_x b_x + a_y b_y + a_z b_z and use a · b = |a||b|cos θ to find the angle between two 3D vectors.
- Use the scalar product to test perpendicularity: a · b = 0 exactly when non-zero vectors a and b are perpendicular.
- calculating the resultant of multiple 3D force vectors by summing Cartesian components
- applying Newton's second law ΣF = ma in three dimensions to find acceleration
- applying 3D vector kinematics or calculus to find velocity or position vectors at time t
- calculating speed as the magnitude of the velocity vector |v| = √(v_x² + v_y² + v_z²)
Examiner Tips
- 💡Use column vector notation (x, y, z)ᵀ to keep the i, j and k components aligned and reduce transcription errors.
- 💡To find an angle, compute the scalar product and both magnitudes separately before dividing; this makes each step checkable and earns method marks even if the final value is wrong.
- 💡Keep components separated in column vector form: (x, y, z)ᵀ makes 3D calculations clean and error-free.
- 💡If asked for the speed of an aircraft, compute the magnitude of the velocity vector: √(v_x² + v_y² + v_z²).
Common Mistakes
- Omitting the z-component when computing magnitudes or distances in three dimensions; the correction is to include all three squared components under the square root.
- Subtracting position vectors in the reverse order when finding displacement AB; the correction is to use B − A, since AB means from A to B.
- Forgetting to divide by both magnitudes when finding an angle, using cos θ = a · b instead of cos θ = (a · b)/(|a||b|); the correction is to compute |a| and |b| first and divide by their product.
- confusing velocity (a 3D vector) with speed (the scalar magnitude |v|)
- omitting the initial position vector r₀ when calculating position from displacement in 3D